How this works
Every live preview comes from an upstream robot-description repository pinned to a commit. A later upstream change therefore cannot silently alter the assembly shown here.
When a vendor ships only xacro, the card is a labeled recipe-produced preview bound to that exact command and configuration; it is not an upstream-published standalone model.
The reference index still records official packages that remain unexpanded.
The browser reads the URDF, resolves each <visual> mesh against the same commit, and applies the joint tree. What you see is the publisher's kinematics, not a single exported scene file.
Visual meshes arrive as STL, Collada (.dae), or binary glTF (.glb). STL carries no colour, so those links are shaded with the material the URDF declares, or a neutral grey where it declares none.
The static render, the licence, and the source links are the whole card. The interactive control is added only when a viewer can actually run, and the 3D engine is downloaded only when you ask for a model.
A separate workspace, Robot inspector, loads any catalogue model and expands upstream joint ids (LHipP, left_hip_pitch_joint) into readable names.
It is the same engine and the same commit-pinned files, not a second model set.
Engineering-description reference index
Publication comparison, not hardware. Comparable fields are formats and assembly state. “Source-only” means xacro, configuration, or a license-sensitive download is required before this browser can assemble the files.
| Upstream identity | Region | Physical class | Published formats | Browser state | License boundary |
|---|---|---|---|---|---|
| Booster K1 (22-DoF description)# | China [M20] | biped / humanoid | URDF, MuJoCo XML [M20] | live preview | BSD-3-Clause [M20] |
| Booster T1 (23- and 29-DoF descriptions)# | China [M20] | biped / humanoid | URDF, MuJoCo XML; 29-DoF URDF [M20] | live preview | BSD-3-Clause [M20] |
| Booster T2 (31-DoF description)# | China [M20] | biped / humanoid | URDF, MuJoCo XML [M20] | live preview | BSD-3-Clause [M20] |
| LimX HU_D04 (publisher model id)# | China [M21] | full-size humanoid | URDF, SRDF, MJCF, USD; gripper and hand URDF/USD variants [M21] | live base preview | Apache-2.0 [M21] |
| LimX TRON2A family# | China [M22] | modular: dual-arm, wheel-foot, sole-foot, combined bodies | URDF / xacro, MJCF, USD [M22] | source-only; variants remain separate classes | Apache-2.0 [M22] |
| Leju Kuavo ROS descriptions# | China [M23] | biped / humanoid configurations | xacro / URDF, MuJoCo, Gazebo, Isaac Sim resources [M23] | source-only; version/config generated | no repository-root license declared [M23] |
| Berkeley Humanoid Lite# | United States [M25] | open research humanoid | URDF, MJCF, USD [M25] | live preview | CC BY-SA 4.0 assets [M25] |
| ToddlerBot 2XC# | United States [M26] | open miniature humanoid | URDF, MJCF, Onshape / printable assets [M26] | live preview | MIT code; CC BY-NC-SA 4.0 design/assets [M26] |
| NASA Valkyrie description# | United States [M27] | research humanoid | xacro + meshes; catkin generates the complete URDF [M27] | source-only; ROS build required | NASA 1.3 [M27] |
| Upstream identity | Region | Physical class | Published formats | Browser state | License boundary |
|---|---|---|---|---|---|
| Hello Robot Stretch 3 / SE3# | United States [M28] | wheeled mobile manipulator | checked-in URDF + STL; SE3 standard gripper sg3 [M28] | live preview | Clear BSD [M28] |
| Hello Robot Stretch 4 / SE4# | United States [M24] | wheeled mobile manipulator | composable xacro + STL; Python exports configured URDF [M24] | source-only; composition required | Clear BSD [M24] |
| Fetch Robotics Fetch# | United States [M29] | wheeled mobile manipulator | checked-in URDF + Collada / STL [M29] | live preview | CC BY-NC-SA 4.0 assets [M29] |
Wheeled mobile manipulators 4 models
Wheeled bases with a lifting or telescoping torso and one or two arms. Payload on a specification sheet is a wrist-centre arm rating, never a chassis rating. These cards are publication evidence only.
-
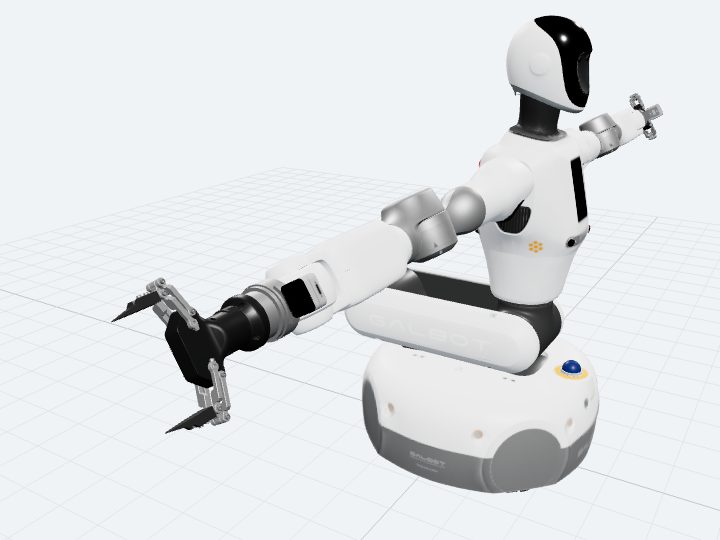
Galbot G1 golf configuration
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Galbot G1 specification sheet
Omni-wheel joints are continuous, without published finite limits. Finger joints mimic the gripper drive joints.
-
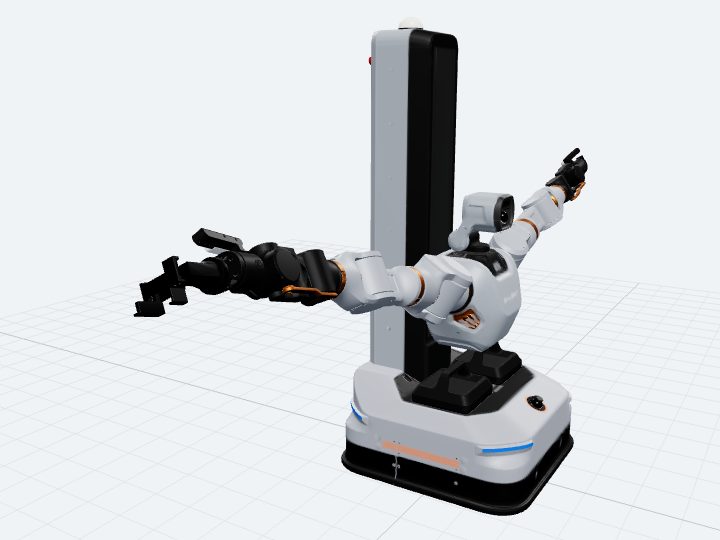
Galbot S1
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Galbot S1 specification sheet
Drive wheels are continuous, without published finite limits. Official gripper fingers mimic the active gripper joints.
-
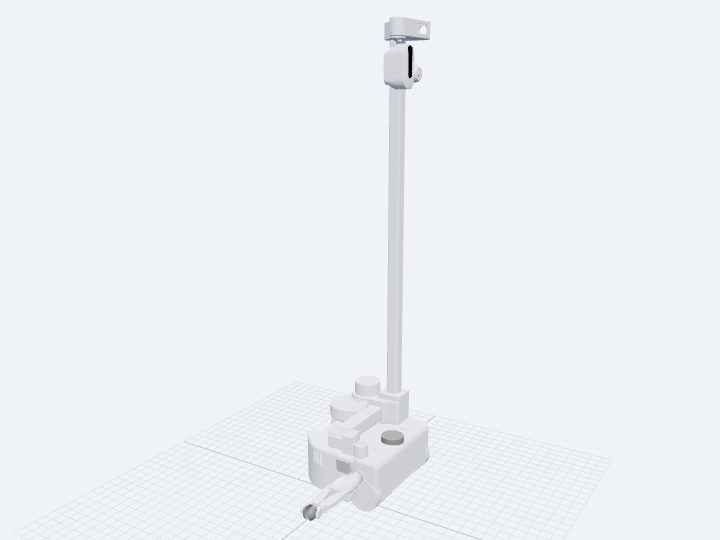
Hello Robot Stretch 3 SE3, wrist dw3, tool sg3
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Stretch 3 specification sheet
This is the checked-in SE3 standard-gripper assembly. It is not Stretch 4 / SE4, which still requires xacro composition, and not the tablet, nil, or pro tool variants in the same repository.
-
Live load only. The upstream
fetch_descriptionpackage declares CC BY-NC-SA 4.0, so this site links and assembles the official URDF in-browser without publishing a derived static render.Fetch Robotics Fetch
Live load only. Nothing from this model is re-hosted on this site.
URDF file · Visual meshes · no specification sheet in this landscape
Official Fetch description on the
ros1default branch. This is not Freight and not a Galbot G1 stand-in. Prismatic lift and gripper joints are the publisher's limits, not a payload claim.


Bipeds and humanoids 20 models
Bipeds. The zero pose in a URDF is the vendor's kinematic reference, not a marketing pose: arms sit where the joint origins put them.
-
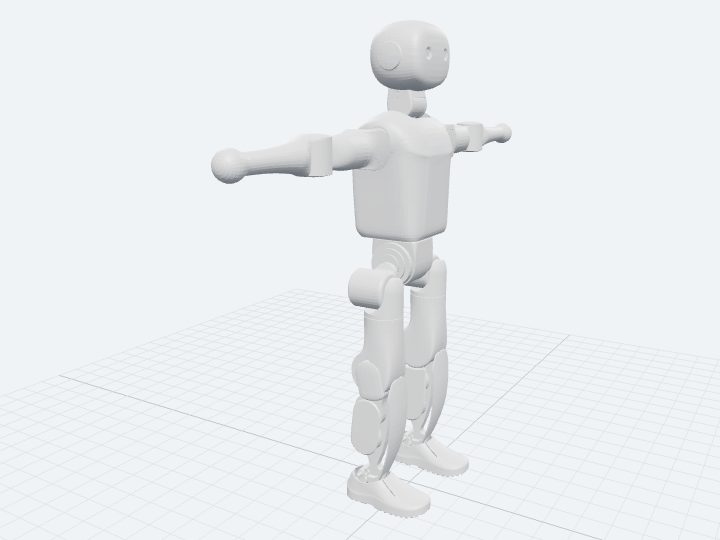
Booster K1 22-DoF description
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Booster K1 specification sheet
This card is the official
K1_22dof.urdfonly. It is not Booster T1 or T2. Official joint identifiers include anaaprefix on the head and some shoulder joints. This 22-DoF assembly has no dexterous hands. -
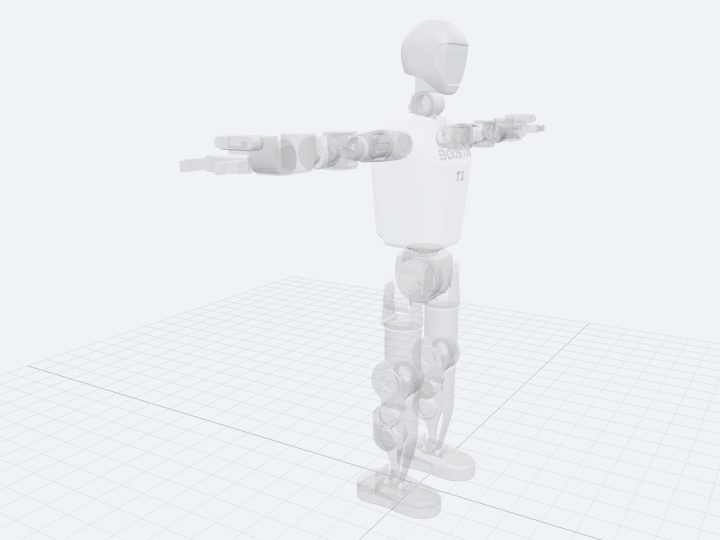
Booster T1 29-DoF description
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Booster T1 specification sheet
This card is the official
T1_29dof.urdfonly. It is not Booster K1 or T2 and not a second count ofT1_23dof.urdf.The official robot name in this file is
T1_7dof. Official joint identifiers include anaaprefix on the head joints. Wrist-roll joints are the distal actuated arm joints; this file has no actuated fingers.The ghosted appearance is upstream data, not a capture defect: most T1 materials declare alpha 0.2 or 0.3 in both the 23- and 29-DoF URDFs.
-
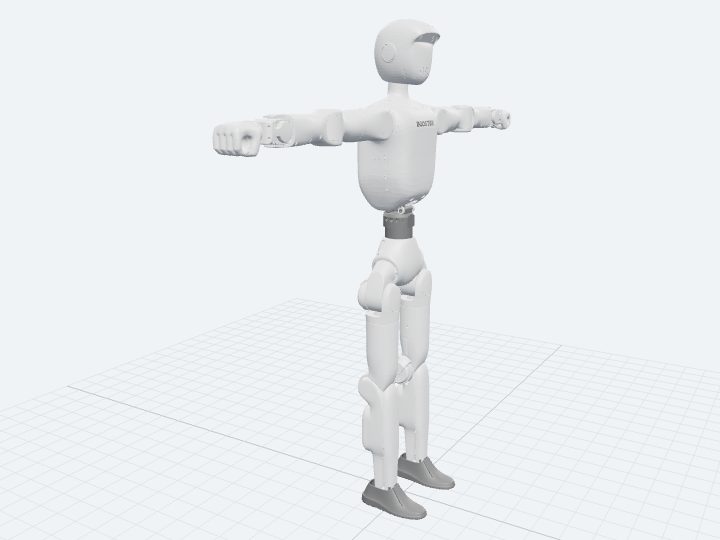
Booster T2 31-DoF description
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no T2 specification sheet in this landscape
-
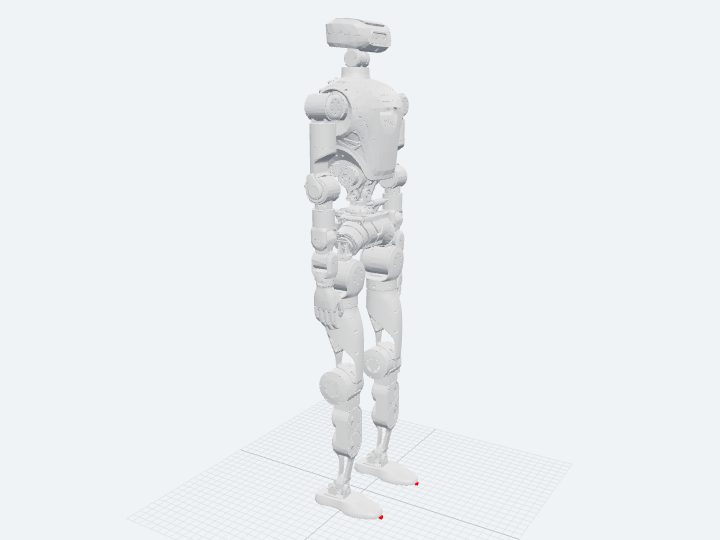
LimX HU_D04 base publisher model id
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · model id is not mapped here to the Oli product name
The upstream README names this artifact HU_D04. It does not map HU_D04 to Oli; this card is HU_D04, not Oli.
This card is
HU_D04_01.urdfonly; sibling gripper and dexterous-hand files are not this assembly. This URDF has no actuated fingers.left_hand_contact/left_hand_manipand the right counterparts are fixed frames without visuals. The package.xml license field is TODO; the repository LICENSE is Apache-2.0. -
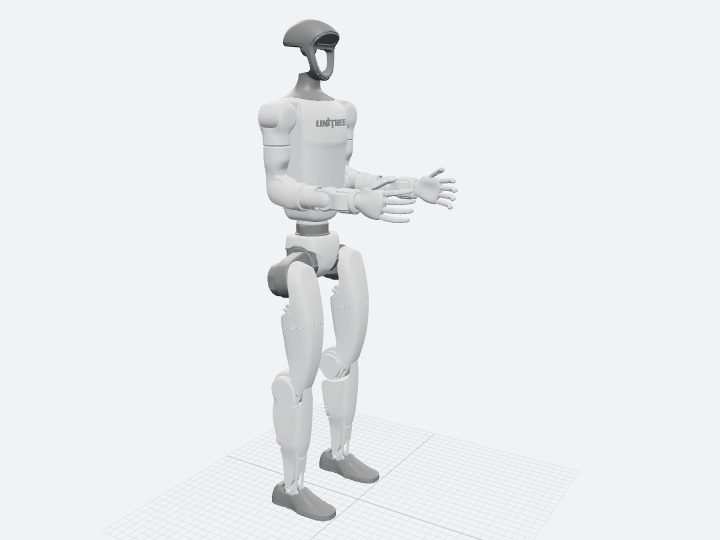
Unitree G1 29-DoF
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree biped family sheet
Official
g1_29dof.urdfwhole assembly. The 23-DoF and three-finger-hand files are variants, not extra robots.Palms are fixed moulded hands. The inspector excludes the official floating
floating_base_jointfrom mechanical travel. -
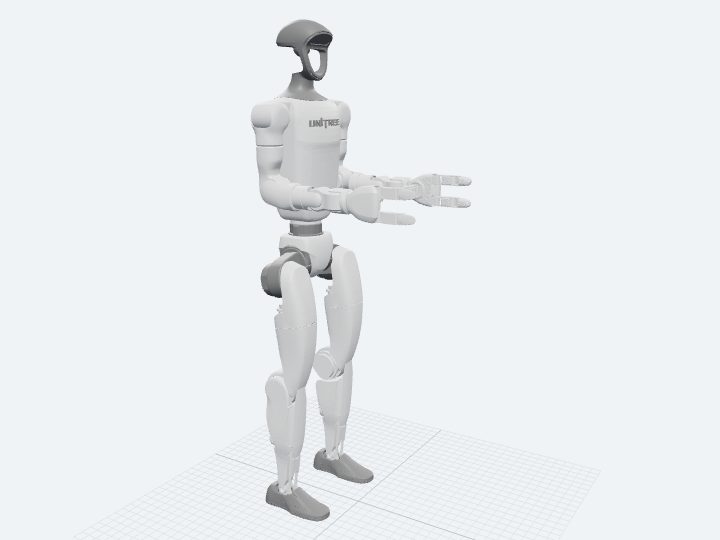
Unitree G1 29-DoF, three-finger hands
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree biped family sheet
-
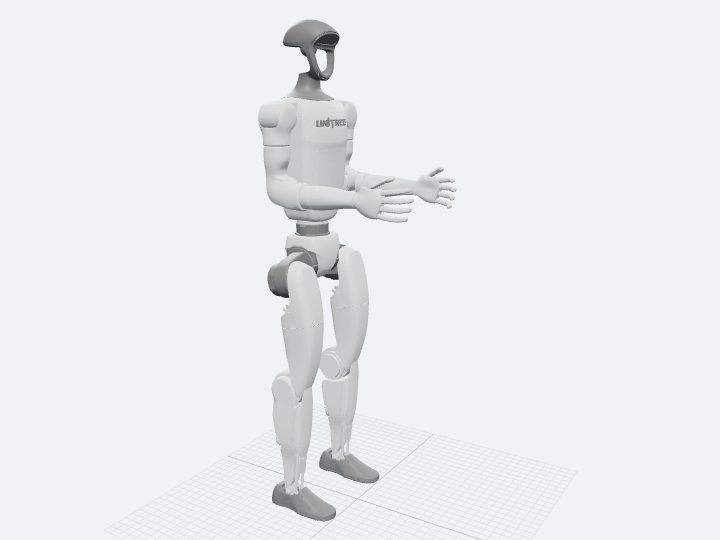
Unitree G1 23-DoF
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree biped family sheet
-
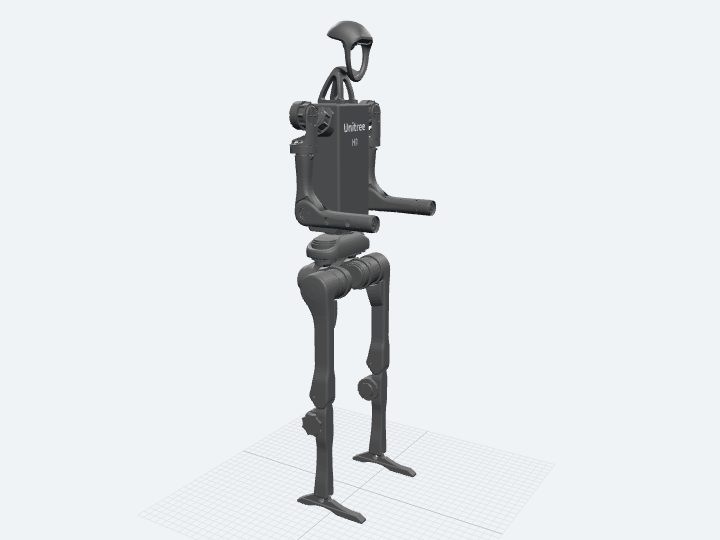
Unitree H1
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree biped family sheet
This is the official
h1.urdfwithout hands. It is not H1-2 and not the HumanoidBenchh1handassembly.The browser preview is the official URDF default (zeros inside published limits), not a calibrated home and not HumanoidBench native qpos.
-
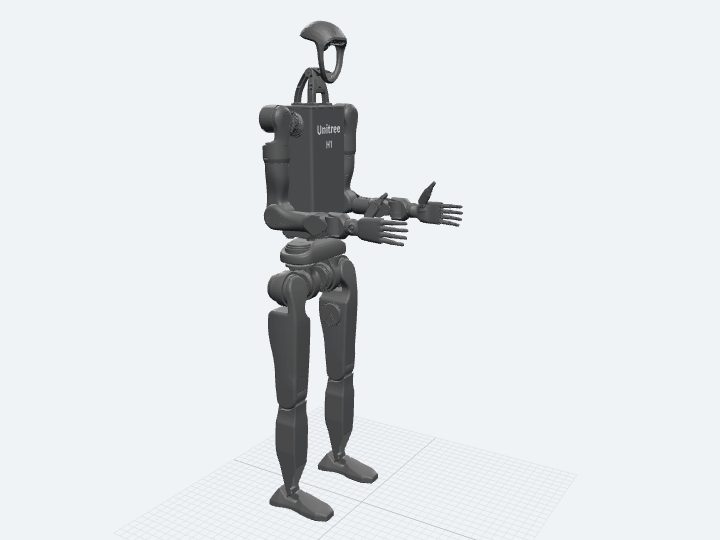
Unitree H1-2
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree biped family sheet
-
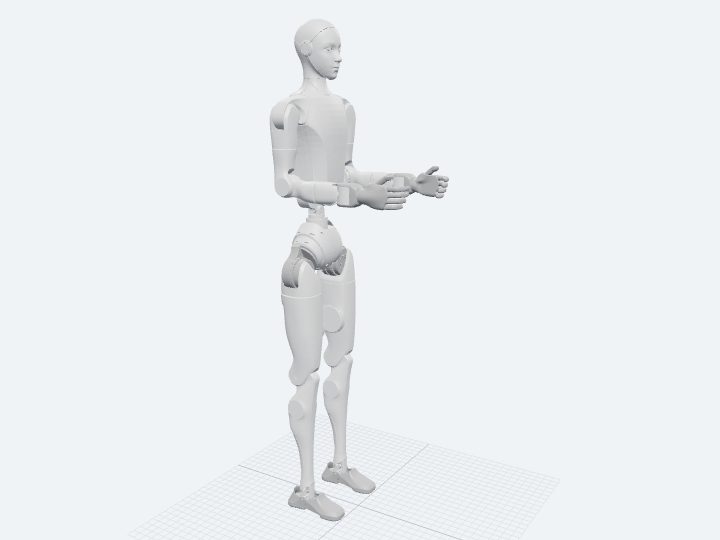
Unitree H2
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree biped family sheet
This is the official
H2.urdf. It is not H1 or H1-2 and not the siblingH2_dae.urdforH2_loop.urdffiles.left_hand_jointandright_hand_jointare fixed; this file has no actuated fingers.h2_descriptionhas no package.xml; mesh URIs are relativemeshes/paths. -
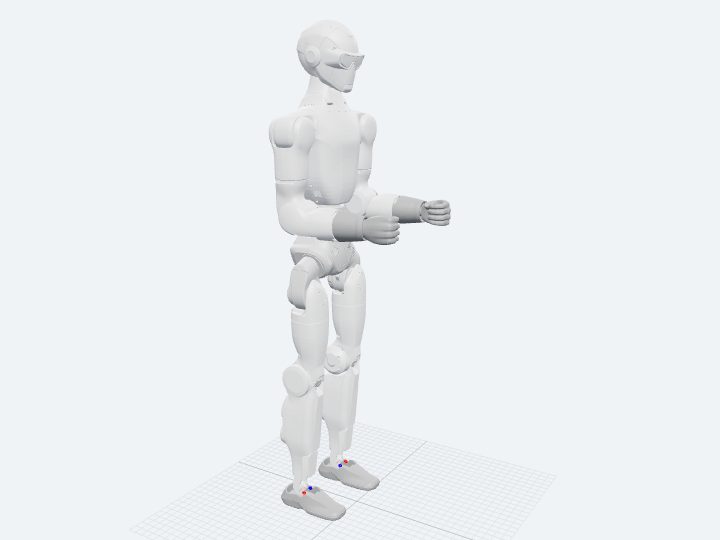
Unitree R1
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree biped family sheet
This is the official
R1.urdfstandard assembly. It is not R1 AIR.Ankle A/B rod and constraint links are fixed linkage visuals, not extra actuated ankles. Wrist-roll joints are the distal actuated arm joints; this file has no actuated fingers.
r1_descriptionhas no package.xml; mesh URIs are relativemeshes/paths. -
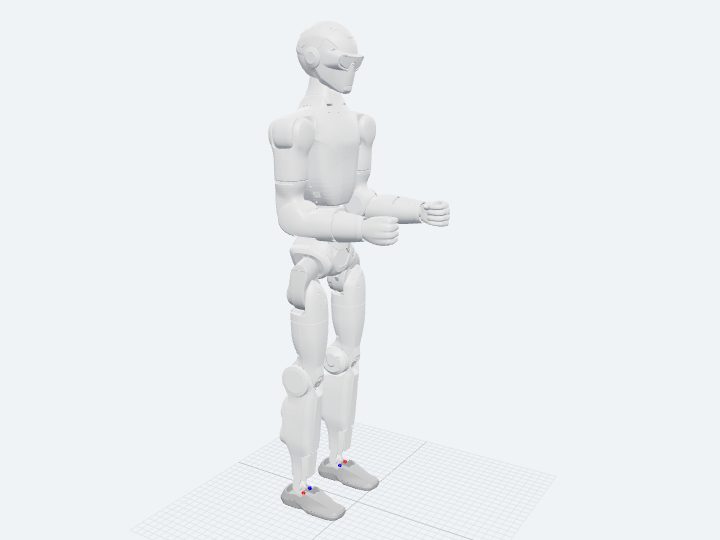
Unitree R1 AIR
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree biped family sheet
-
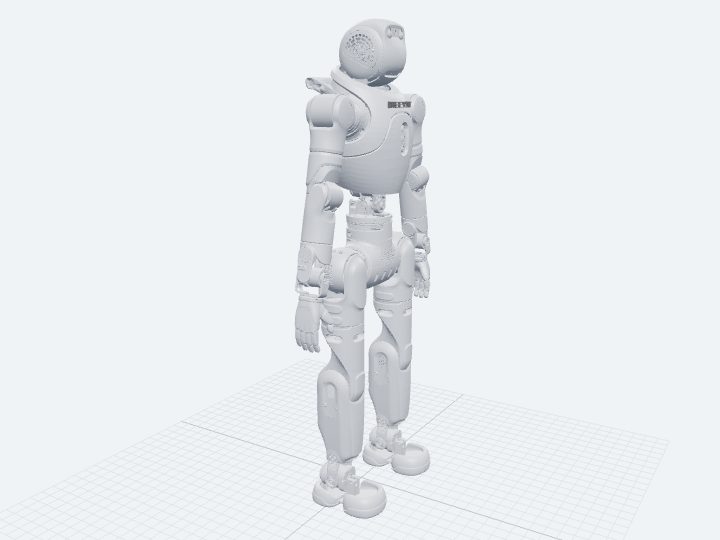
AgiBot X2 Ultra URDF v1.4.0
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · AgiBot X2 family sheet
AgiBot's README maps this file to the nameplate reading “X2 Ultra -N”; the v1.3.0 directory holds the earlier X2 Ultra. This is not AgiBot A3 and not the A2 reseller column.
Wrist-roll joints are the distal actuated arm joints; this file has no actuated fingers.
-
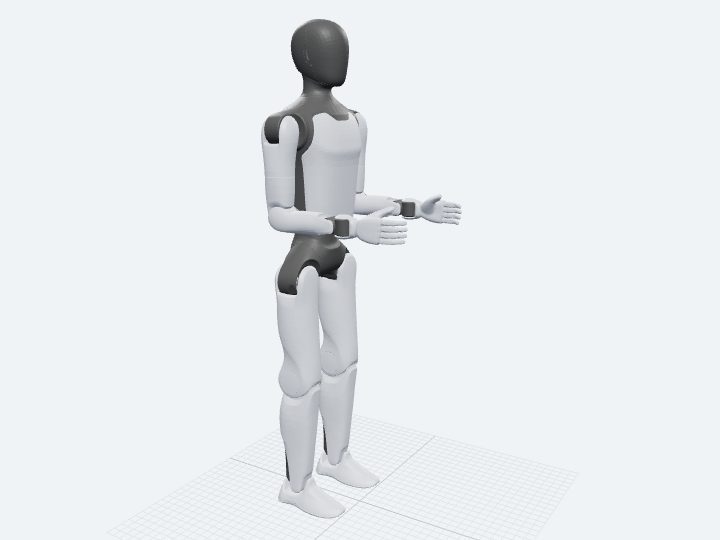
AgiBot A3 T3.0
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
This card is
a3_t3d0/urdf/model.urdfonly. It is not A3 Ultra, not the T2.5 directories, and not AgiBot X2 Ultra.The official robot name in this file is
A3T3.left_hand_jointandright_hand_jointare fixed; this file has no actuated fingers.LICENSE.txtis Mulan PSL v2. -
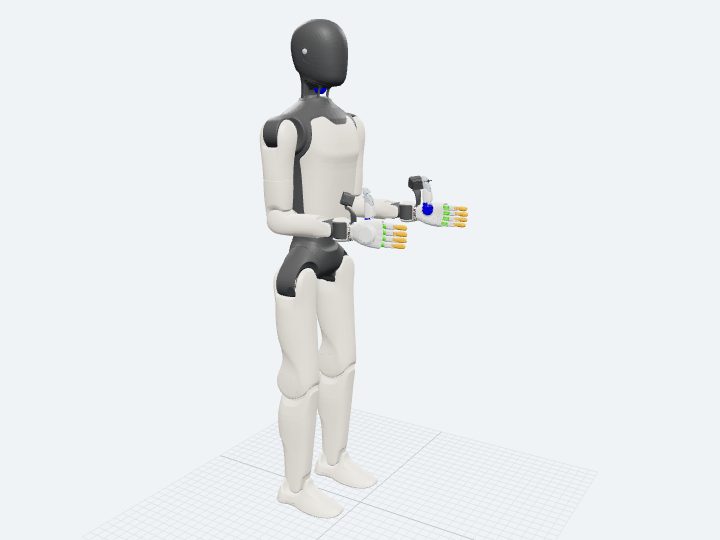
AgiBot A3 Ultra T3.0
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
The A3 Ultra directory adds dexterous-hand assets over the base A3.
-
No static render is published for this model. Its assets are GPL-3.0, so the preview is loaded live from the vendor repository instead of re-hosted here.
Fourier GR1T1 body, no end-effector
Live load only. Nothing from this model is re-hosted on this site.
URDF file · Visual meshes · no specification sheet in this landscape
Fourier's name table maps code name GR1T1 to product GR-1 (dexterous hand) or GR-1L (jaw). This basic URDF ends at the end-effector link, so it carries neither.
-
No static render is published for this model. Its assets are GPL-3.0, so the preview is loaded live from the vendor repository instead of re-hosted here.
Fourier GR1T2 body, no end-effector
Live load only. Nothing from this model is re-hosted on this site.
URDF file · Visual meshes · no specification sheet in this landscape
Fourier's name table maps code name GR1T2 to product GR-1 Pro (dexterous hand) or GR-1L Pro (jaw).
-
No static render is published for this model. Its assets are GPL-3.0, so the preview is loaded live from the vendor repository instead of re-hosted here.
Fourier GR2 v3.0.1
Live load only. Nothing from this model is re-hosted on this site.
URDF file · Visual meshes · Fourier GR-2 specification sheet
This card is
GR2v3.0.1.urdfonly. It is not GR1T1 or GR1T2. Wrist-roll links carry the published hand meshes. This file has no actuated finger joints. -
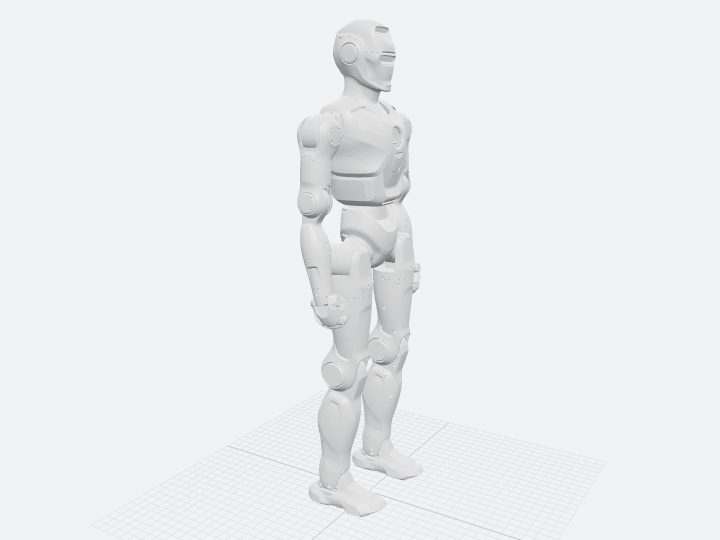
EngineAI PM01 serial revision 2
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
This card is
serial_pm_v2.urdfonly. It is not a second Education or Navigation DoF column.Official mesh URIs use
package://resource/...against the MuJoCoassets/resourcetree; that directory has no package.xml, soresourceis a path token rather than a ROS package.Elbow ends and feet are fixed empty frames. This URDF has no actuated hands.
-
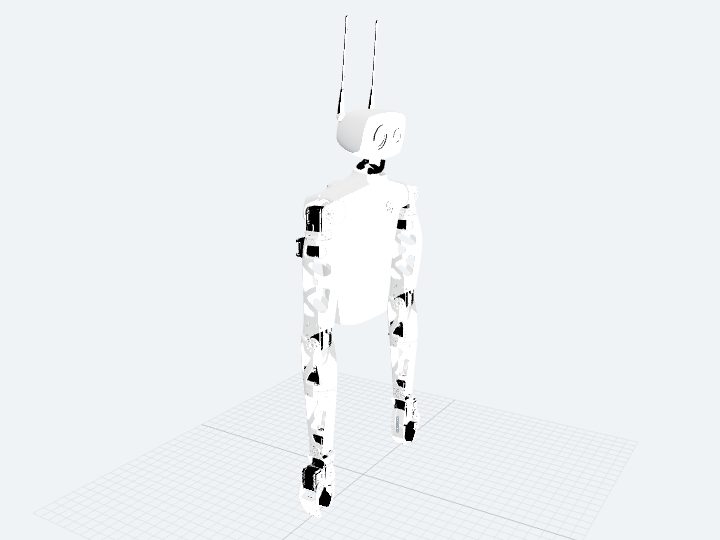
Reachy v1
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no v1 specification sheet in this landscape
This is Reachy v1, not Reachy 2 and not Reachy Mini. The official pedestal joint is fixed; this URDF has no drive-wheel joints. Parallel-jaw grippers and antenna joints are in the official file.


Mobile robot bases 2 models
Drive bases published as a complete description. A base carries no arm, so the zero pose is the whole robot.
-
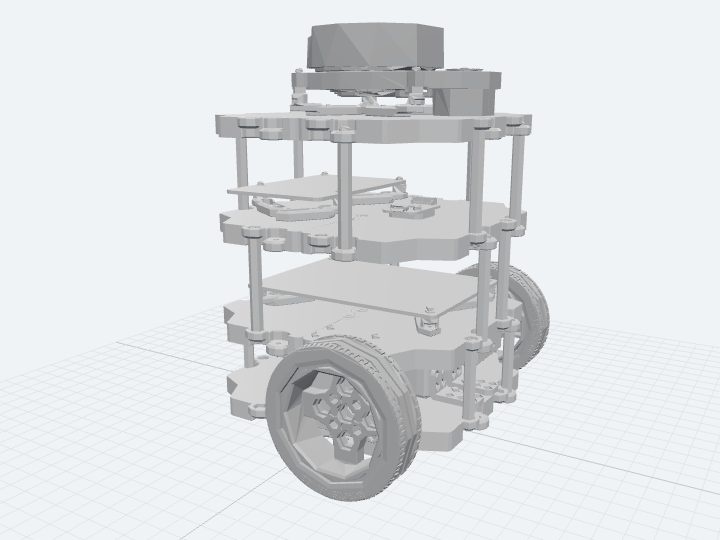
TurtleBot3 Burger
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
The official burger URDF still contains an empty-default xacro namespace token in link and joint names. Drive wheels are continuous and have no published finite limits.
-
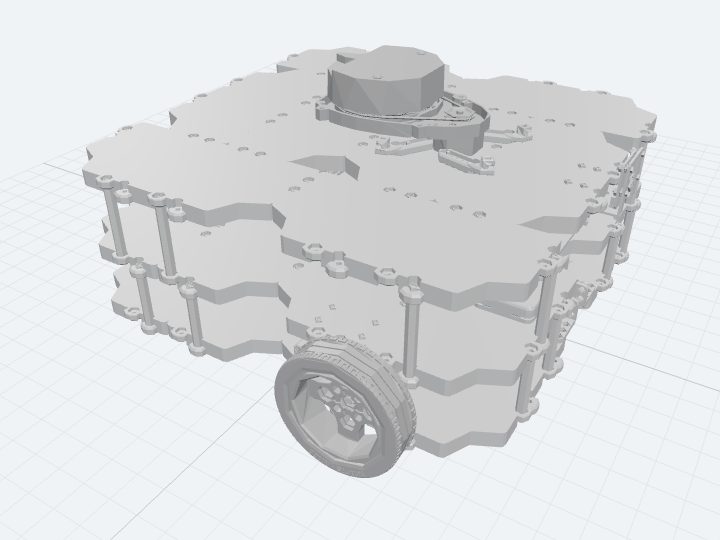
TurtleBot3 Waffle Pi
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
This is Waffle Pi, not Burger. The official file uses
waffle_pi_base, two casters, and a Raspberry Pi camera chain.The empty-default xacro namespace token remains in link and joint names. Drive wheels are continuous and have no published finite limits.


Quadrupeds 7 models
Four-legged platforms, including wheeled-foot B2-W and Go2-W. ANYmal B and ANYmal C cards are simplified simulation descriptions, not production C or Generation D.
-
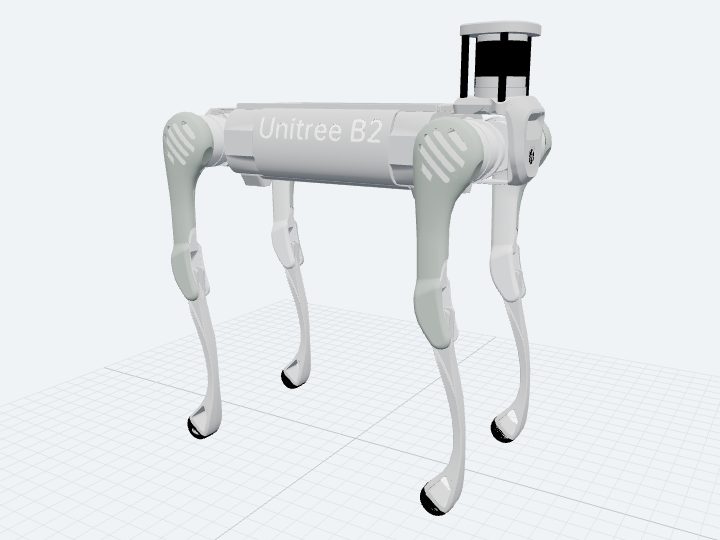
Unitree B2
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree B2 specification sheet
This card is the official
b2_description.urdffoot assembly. It is not B2-W. Foot links are fixed empty frames. This file has no drive-wheel joints. -
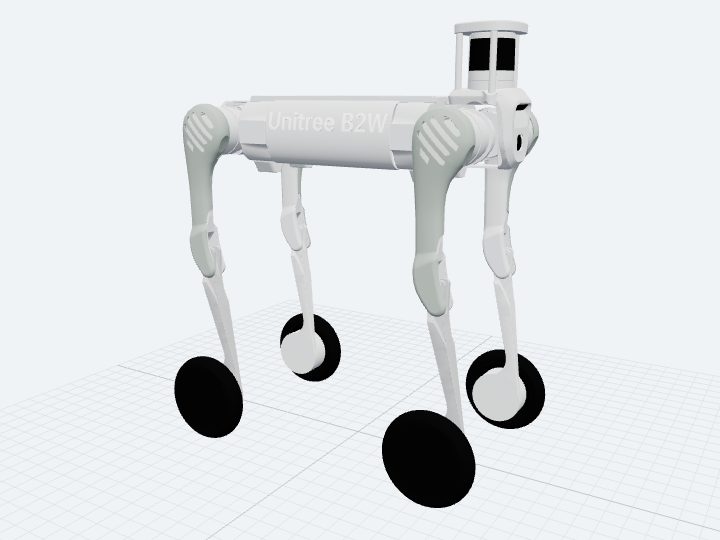
Unitree B2-W
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree B2-W specification sheet
-
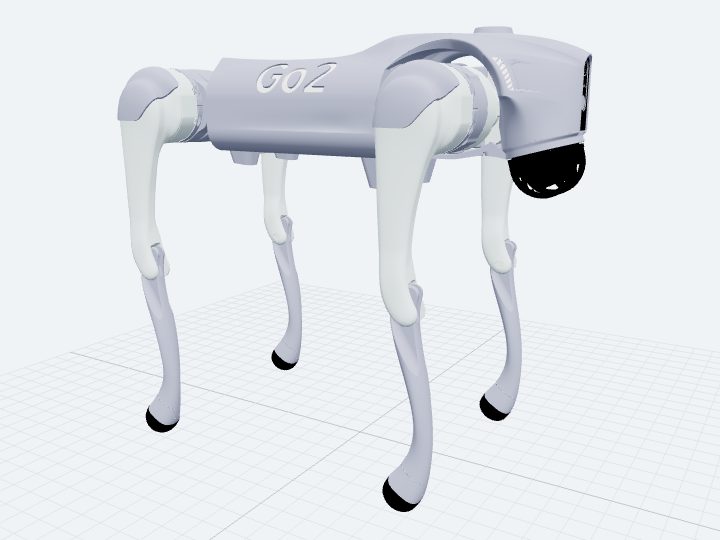
Unitree Go2
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Unitree Go2 family sheet
-
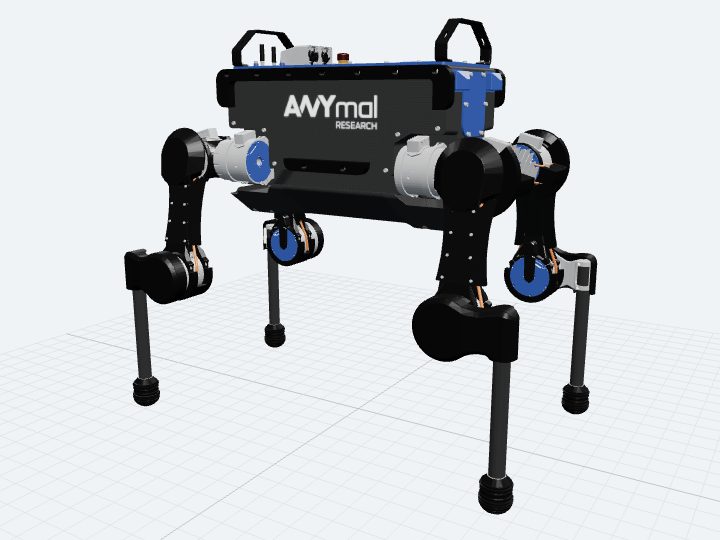
ANYbotics ANYmal B simple description
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
ANYbotics publishes this as a simplified description for simulation, not as the production ANYmal C or D.
-
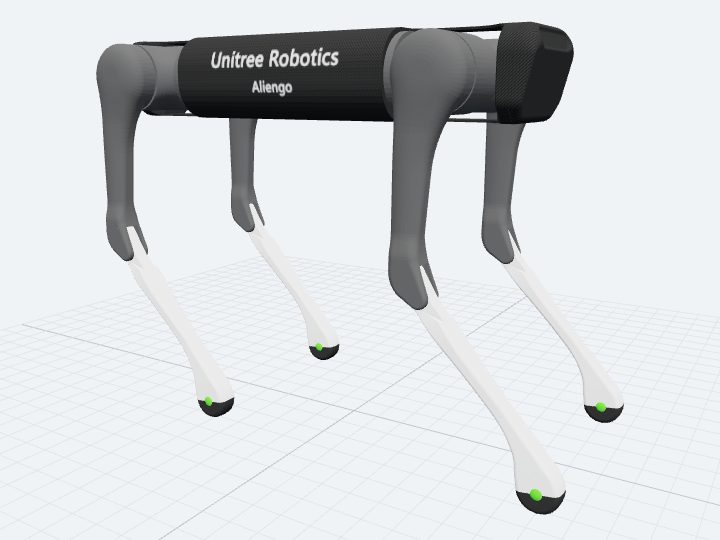
Unitree Aliengo
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
A distinct research quadruped in the same Unitree ROS pin as Go2. It is not Go2, B2, or a renamed copy.
-
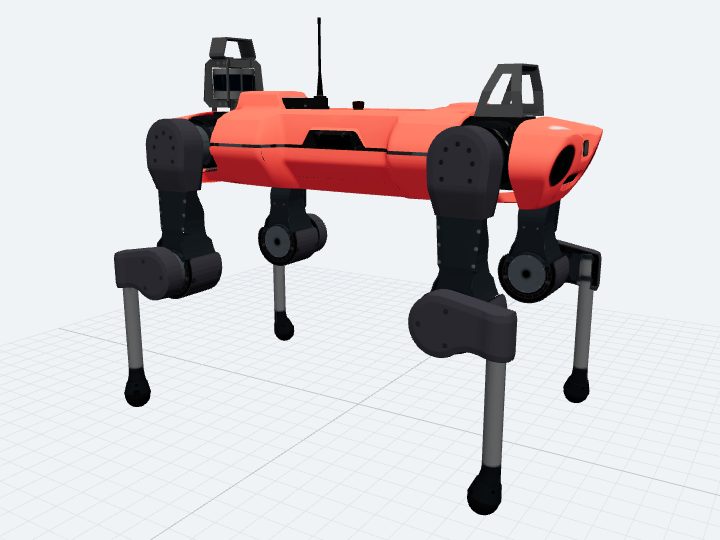
ANYbotics ANYmal C simple description
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
ANYbotics publishes this as a simplified simulation description. It is not production ANYmal C, not Generation D, and not the ANYmal B simple-description card.
-
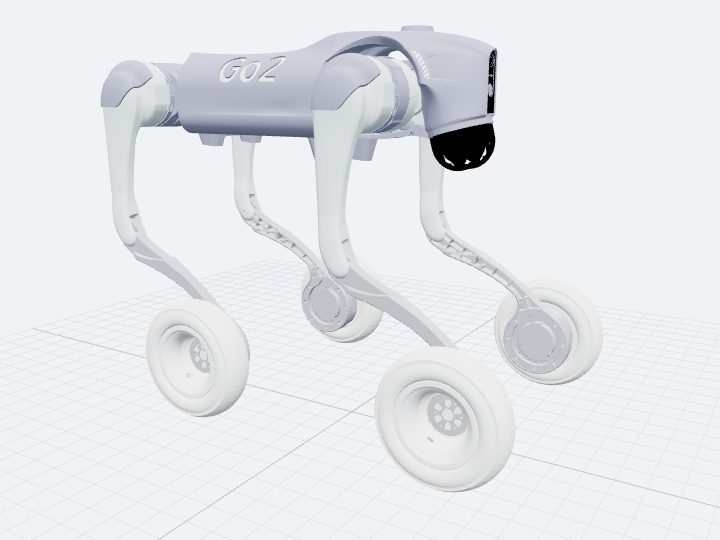
Unitree Go2-W
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
Wheeled-foot Go2 description. It is not the footed Go2 card and not the industrial B2-W.


Robot arms 6 models
Fixed-base manipulators. Kinova Gen3 is a checked-in vendor URDF. Franka Research 3 and UR5e are labeled recipe-produced previews from the vendor xacro entrypoints; they are not upstream-published standalone models.
UR20 remains in the gaps list because its meshes use Graphical Documentation terms.
-
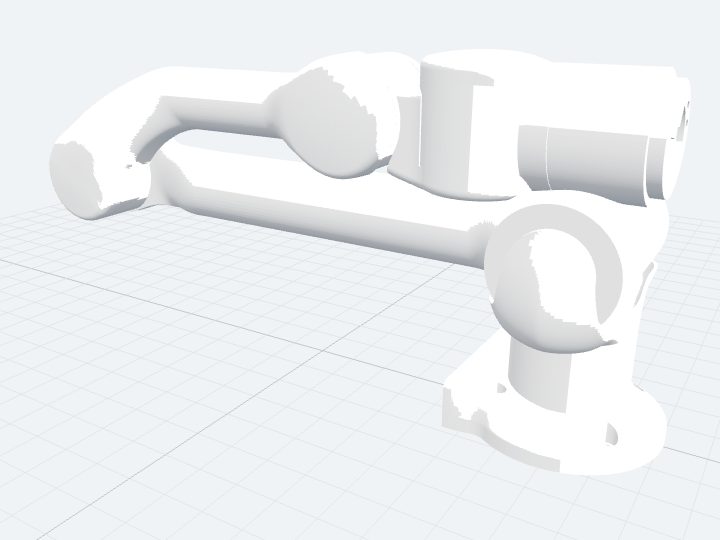
Unitree Z1
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
The checked-in file in
xacro/is a complete generated URDF and is not regenerated here. This assembly is a six-joint arm with no gripper. The first pose is a browser preview, not a calibrated home. -
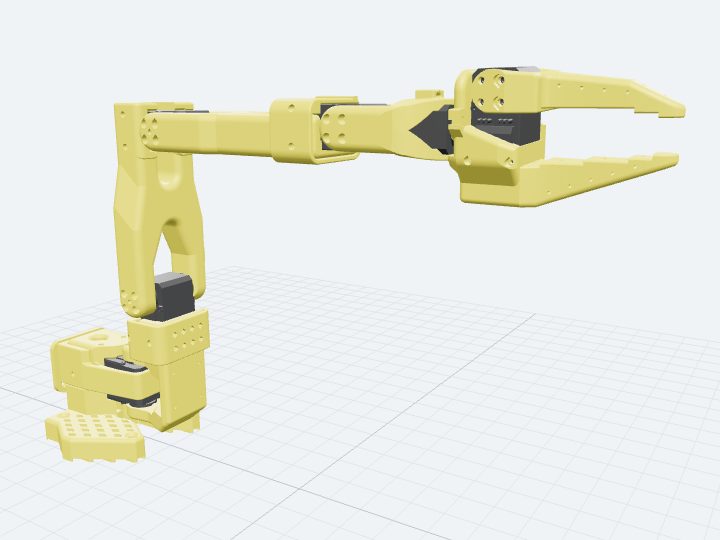
SO-ARM101 new calibration
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
This is the SO101 new-calibration URDF. It is not the SO100 model in the same repository.
-
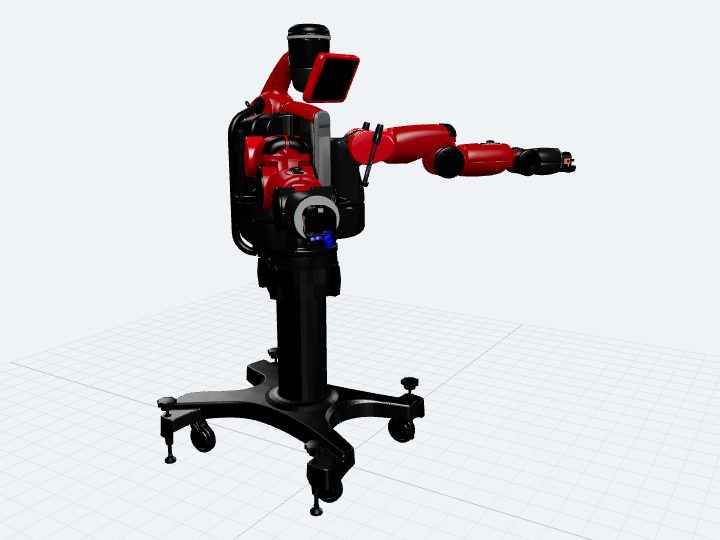
Baxter
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
Official
baxter.urdfis a dual-arm pedestal assembly. The pedestal joint is fixed and there are no drive-wheel joints.left_gripper_baseandright_gripper_baseare fixed; this file has no actuated finger joints. -
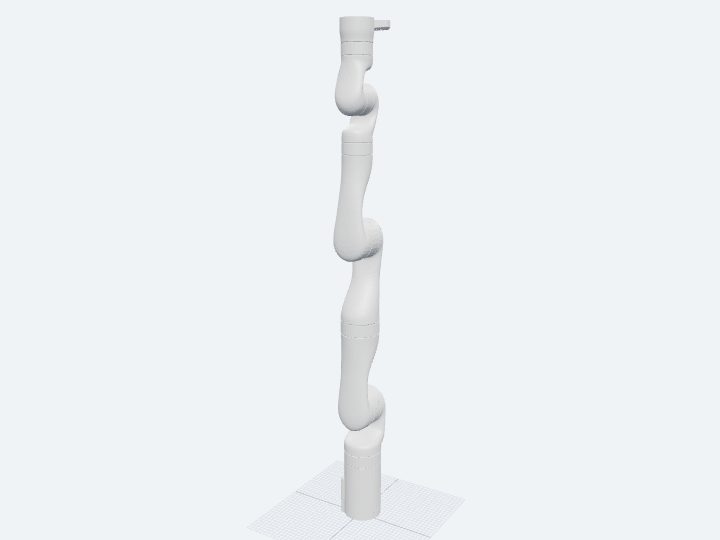
Kinova Gen3 7-DoF vision
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
This card is
GEN3-7DOF-VISION_ARM_URDF_V12.urdfonly. NOVISION and BRAKES files are not counted separately. This file has no gripper.joint_1,joint_3,joint_5, andjoint_7are continuous and have no published finite mechanical limits. -
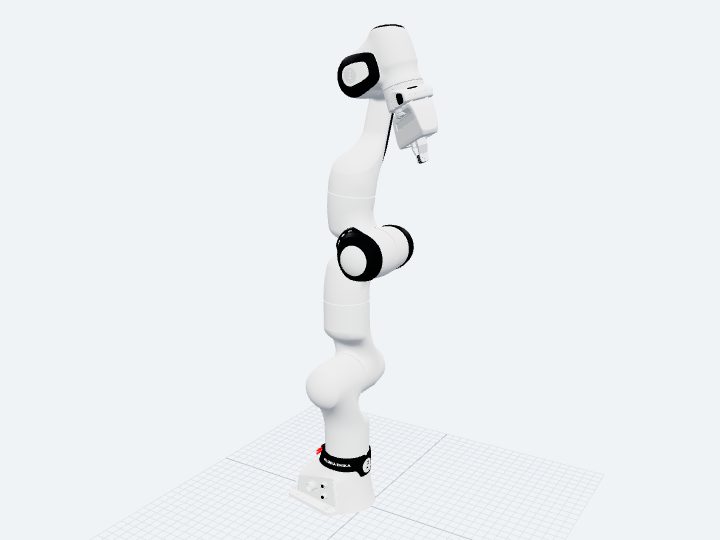
Franka Research 3 FR3 + Hand
Recipe-produced preview from the vendor
create_urdf.pycommand. This XML is not an upstream-published standalone model.Vendor recipe · Provenance · Visual meshes · FR3 specification sheet
This is FR3, not FR3v2, FP3, FER/Panda, or FR3 Duo. No payload or calibrated home is taken from this file.
Exact command:
python3 scripts/create_urdf.py fr3 --robot-ee franka_handat commit 7aeeddc. Meshes staypackage://franka_description/...on the vendor pin. -
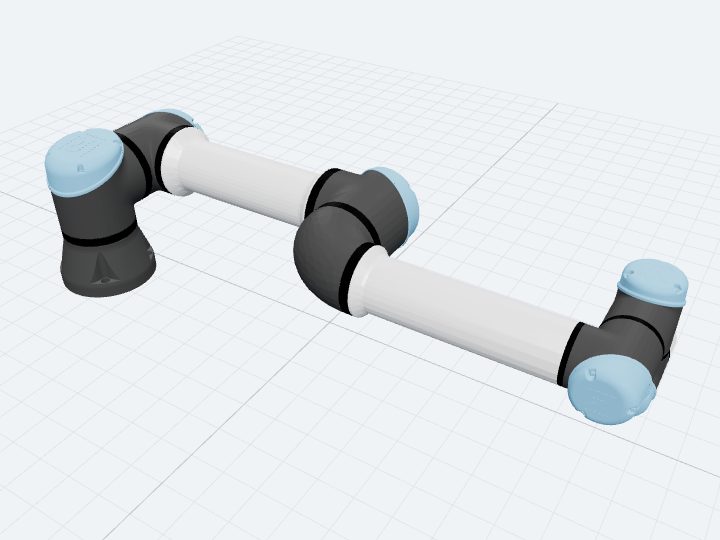
UR5e
Recipe-produced preview from the vendor
view_ur.launch.xmlxacro command. This XML is not an upstream-published standalone model.Vendor recipe · Provenance · Visual meshes · no UR5e specification sheet in this landscape
This is UR5e, not UR5 or UR20. UR5e meshes are BSD-3-Clause. No gripper is included.
Exact command:
xacro urdf/ur.urdf.xacro ur_type:=ur5e name:=ur safety_limits:=true safety_pos_margin:=0.15 safety_k_position:=20 tf_prefix:=at commit 89bbe79.Kinematics come from
config/ur5e/default_kinematics.yaml, the generic factory default, not a calibrated robot.


Hands and end-effectors 3 models
End-effectors, not robot platforms. A hand's grasp load never adds to an arm payload.
-
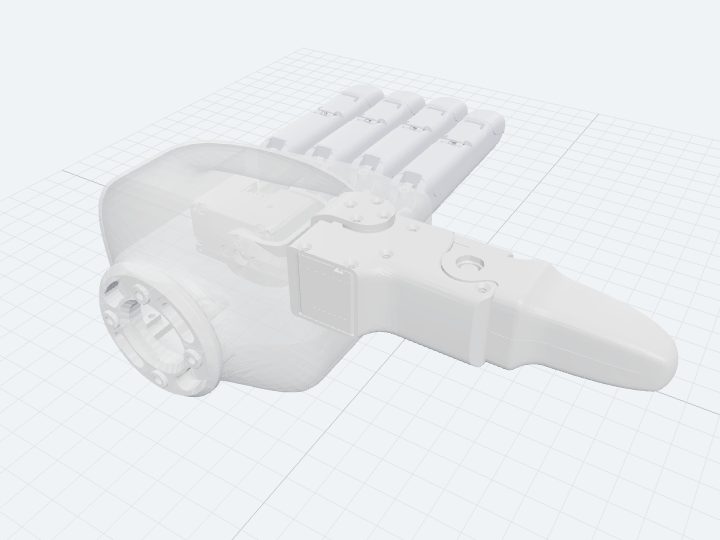
Unitree Dex5-1 right hand
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · Dex5-1 component sheet
-
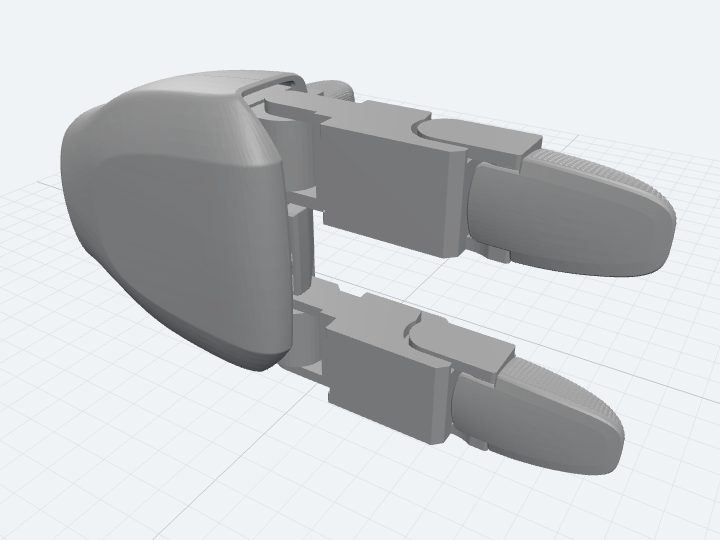
Unitree Dex3-1 right hand
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape
-
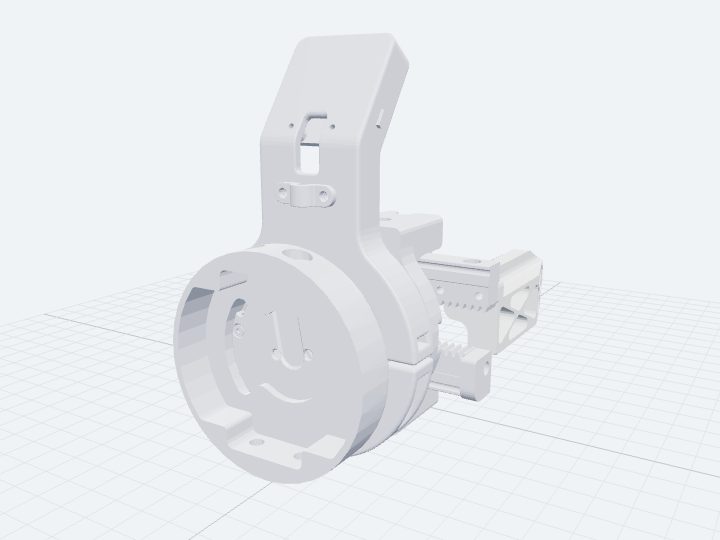
Unitree Dex1-1 gripper
Static render of the official URDF, produced by this page's viewer from the commit-pinned vendor files linked below.
URDF file · Visual meshes · no specification sheet in this landscape


Open research hardware 2 models
Research platforms are kept separate from commercial robot families. The model repository establishes an inspectable kinematic artifact; paper performance and build cost remain on the research-systems page.
-
Live load only. The upstream asset package is CC BY-SA 4.0, so this site links and assembles it in-browser without publishing a derived static render.
Berkeley Humanoid Lite full-body URDF
Live load only. Nothing from this model is re-hosted on this page.
URDF file · Visual meshes · Research hardware sheet
Upstream
LICENCEis CC BY-SA 4.0. Official mesh URIs arepackage://../meshes/...path tokens, not a ROS package.xml.arm_left_hand_landarm_hand_rare fixed links; this URDF has no actuated hands.Official
imu_frameis a fixed joint withaxis xyz="0 0 0"; the shared viewer drops that unusable axis so the loader does not dereference it. -
Live load only. ToddlerBot's design and STL assets are CC BY-NC-SA 4.0, so this site links and assembles them in-browser without publishing a derived static render.
ToddlerBot 2XC assembly
Live load only. Nothing from this model is re-hosted on this page.
URDF file · Visual meshes · Research hardware sheet
This card is the checked-in
toddlerbot_2xc.urdfonly. Sibling2xmand gripper assemblies are not this family. Design and STL assets are CC BY-NC-SA 4.0; code is MIT.Official
torso_freejointis typefloating; the inspector does not treat that 6-DoF free body, or the publisher ±999999 limits on it, as mechanical travel.Conversion scripts exist in the same tree; this card loads the published URDF and does not regenerate it. Wrist-roll joints are the distal actuated arm joints; this file has no actuated fingers.
Classes with no public model
These are findings, not omissions. Each was checked against the vendor's own channels; none publishes a complete public description that a browser can assemble.
- UR5e is a labeled recipe-produced preview from the official ROS 2 description; UR20 remains here because its meshes use Universal Robots' Graphical Documentation terms rather than the repository's BSD-3-Clause. Repository mixed terms on UR20 [M5] [M33].
- Franka Research 3 is a labeled recipe product on the arms list, not a standalone upstream URDF.
- ABB, FANUC, and KUKA publish CAD through partner portals, not as public robot descriptions.
- Plain URDFs for four KUKA arms do exist and do assemble, but the ROS-Industrial consortium publishes them, not KUKA, so they are not shown here as vendor models. Repository Apache-2.0 [M18]
Boston Dynamics points SDK users to defeatured detailed CAD in its Support Center rather than publishing meshes. No third-party Spot mesh is presented here as a vendor model.
Mechanical interfaces Boston Dynamics SDK terms [M6]
MiR, OTTO, and Locus publish no public engineering model. Their entries stay specification-only. Mobile robots
Blue Robotics links an assembled BlueROV2 CAD view hosted on GrabCAD, under that host's download terms rather than a repository licence, so it is a download and not a preview.
3D model documentation GrabCAD download terms [M7]
Lely, Kärcher, Intuitive, Roborock, and DJI publish none. Full catalogue
Figure, Tesla, Apptronik, and Boston Dynamics Atlas have no public description, consistent with having no public specification sheet.
Galbot ET1 now has a vendor specification table and still no public URDF. Agility Digit exposes simulator and API access, but no official public URDF was verified.